 EN
 EN
 ZH
 IT
 ES
 TH
 TR
 JA
 PT
 KO
 RU
 FR
 DE
 AR
 Home > News Center > Industry news > How to Select a Planetary Reducer for Robotic and Precision Motion Systems
How to Select a Planetary Reducer for Robotic and Precision Motion Systems
In robotic systems, the reducer is not simply a component used to lower motor speed. It directly affects output torque, positioning accuracy, mechanical efficiency, system size, operating life, and the overall response of the robot. For manufacturers of robotic arms, humanoid robots, AGVs, AMRs, automation equipment, and precision motion systems, selecting the right transmission solution can therefore have a significant impact on the final machine.
A planetary reducer is one of the most widely used transmission solutions when a compact structure, high torque density, and controlled backlash are required. However, not every planetary reducer is suitable for every robotic application. The correct selection depends on the motor, load profile, required output speed, positioning accuracy, installation space, duty cycle, and expected service life.
For OEMs and automation integrators, the objective should not be to select a reducer based on one specification alone. A reliable selection process considers the complete transmission system and how the reducer will perform under actual operating conditions.
What Is a Planetary Reducer?
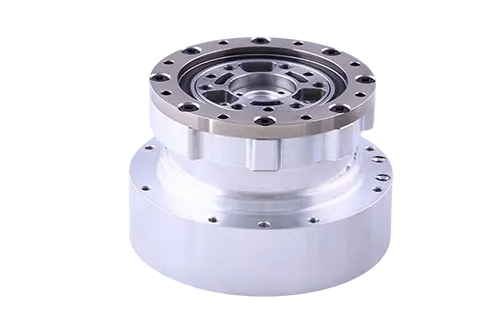
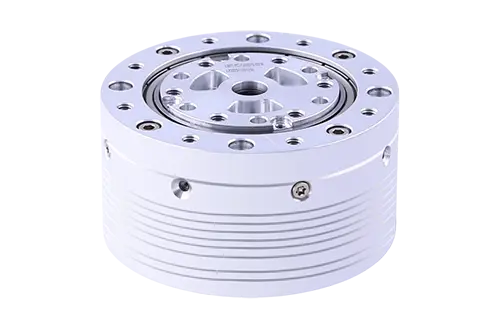
A planetary reducer is a mechanical transmission device that uses a central sun gear, multiple planetary gears, and an outer ring gear to transmit motion. Depending on the design, the planetary gears rotate around the sun gear while also rotating on their own axes. This arrangement distributes the transmitted load across multiple gears instead of concentrating it on a single gear pair.
This load-sharing principle gives planetary transmission systems several advantages for industrial applications. A planetary reducer can provide a relatively high reduction ratio within a compact package while maintaining good torque capacity and mechanical rigidity.
The basic structure typically includes:
Sun gear
Planet gears
Planet carrier
Ring gear
Input and output shafts
Bearings and housing
Lubrication system
The number of stages can also be changed according to the required reduction ratio. A single-stage design may be appropriate for applications requiring a moderate ratio, while multi-stage configurations can provide higher reduction ratios.
For robotics, the design becomes particularly important because the transmission must often handle repeated acceleration, deceleration, reversing, and positioning movements rather than continuous operation at a single speed.
Why Planetary Reducers Are Used in Robotics
Robotic motion systems require a combination of torque, compact dimensions, precision, and repeatability. These requirements make planetary transmission technology useful for many robot and automation applications.
One important characteristic is torque density. Multiple planetary gears share the transmitted load, allowing the reducer to handle substantial torque without requiring an excessively large housing. This is valuable when the available installation space is limited.
Another consideration is mechanical rigidity. A rigid transmission can help reduce unwanted movement between the motor and load. This is particularly relevant when a robot must repeatedly stop at defined positions or maintain a stable load during operation.
A properly designed planetary reducer can also provide a relatively low-backlash transmission solution. For robotic applications, backlash is important because excessive clearance in the transmission can appear as positioning error, mechanical play, or inconsistent movement at the output.
The reducer must also work together with the servo motor, encoder, controller, and mechanical structure. A transmission that performs well in isolation may not deliver the expected results if its characteristics are poorly matched to the rest of the motion system.
Planetary Reducer vs. Other Precision Transmission Solutions
Robot manufacturers may consider several transmission technologies depending on the joint or axis requirements. Planetary reducers, harmonic reducers, cycloidal reducers, and other precision gear systems each have different mechanical characteristics.
A planetary reducer is often considered when the application requires a combination of compact dimensions, torque capacity, efficiency, speed capability, and precision. Harmonic reducers, for example, are widely used in robot joints where very low backlash and compact integration are major priorities. Cycloidal designs may be selected when shock resistance and high torque capacity are important.
The selection should therefore be based on the actual operating requirements rather than assuming that one reducer technology is universally better.
For a robotic joint, the following parameters are particularly important:
Rated output torque
Peak output torque
Reduction ratio
Backlash
Torsional rigidity
Transmission efficiency
Input speed
Output speed
Radial and axial load capacity
Operating temperature
Expected service life
Installation dimensions
Motor compatibility
This comparison is especially important for OEM projects because changing the reducer after the mechanical structure has been finalized can require changes to the motor, housing, mounting interface, bearings, controller parameters, and software.
What Makes a Reducer a Robotic Precision Reducer?
The term "robotic precision reducer" generally refers to a transmission solution designed for applications where controlled positioning, repeatability, and mechanical performance are important.
Precision does not depend on backlash alone. A robotic transmission system also needs predictable behavior under load. Important characteristics include manufacturing accuracy, bearing quality, gear geometry, assembly accuracy, housing rigidity, lubrication, and quality control.
For example, a reducer may have low nominal backlash but still produce inconsistent positioning if manufacturing tolerances are not controlled properly. Similarly, a high reduction ratio does not automatically mean better positioning performance.
When evaluating a robotic precision reducer, buyers should therefore request complete technical specifications rather than relying on a single accuracy figure.
It is useful to ask the supplier for information such as:
Reduction ratio options
Rated and peak torque
Backlash measurement conditions
Torsional rigidity
Permissible radial and axial loads
Maximum input speed
Efficiency data
Operating temperature range
Lubrication requirements
Expected service life
Mounting dimensions
Motor interface specifications
The measurement conditions are also important. Technical values should be compared using equivalent test conditions. Otherwise, two products may appear similar on paper while producing different results in actual applications.
How to Match a Planetary Reducer to the Motor
The reducer and motor should be selected as a matched drive system.
A common mistake is to start with the reducer ratio and then select a motor afterward. For many robotic applications, it is more practical to begin with the required load and motion profile.
Suppose the robot joint requires a specific output torque and speed. The engineer can then determine the approximate motor torque and speed required based on the selected reduction ratio and transmission efficiency.
The basic relationship can be expressed as:
Output torque ≈ Motor torque × Reduction ratio × Efficiency
This relationship is simplified and does not replace detailed engineering calculations, but it illustrates why the reduction ratio has a direct effect on the motor requirements.
A higher ratio can increase available output torque while reducing output speed. A lower ratio can provide higher output speed but may require greater motor torque.
The engineer should also consider peak acceleration torque. A robot joint may experience significantly higher transient loads during rapid acceleration, emergency stopping, collision detection, or changes in payload.
For this reason, selecting a reducer according only to the robot's average load can result in an undersized transmission.
Backlash and Positioning Accuracy
Backlash is one of the first specifications engineers usually check when selecting a precision reducer.
In simple terms, backlash is the relative movement caused by clearance between mating gear components when the direction of rotation changes. In a robot, excessive backlash can reduce positioning consistency, especially when the joint repeatedly changes direction.
However, backlash should be evaluated together with other mechanical characteristics.
Torsional rigidity is another important parameter. When a robot joint is loaded, the transmission may experience elastic deformation. If the system has insufficient rigidity, the output position can change under load even when the encoder indicates that the motor has reached the target position.
Therefore, a robotic precision reducer should be evaluated based on the complete mechanical behavior of the transmission rather than one specification.
For high-precision applications, OEM engineers should also consider whether the reducer maintains its performance throughout the expected operating life. Gear wear, bearing wear, lubrication degradation, and repeated thermal cycles can affect transmission characteristics over time.
Torque Capacity Is Not the Only Sizing Factor
It is tempting to select a reducer by comparing rated torque values. In practice, torque capacity is only one part of the sizing calculation.
A robotic axis may experience several types of loads:
Continuous operating torque
Acceleration torque
Deceleration torque
Static holding torque
Impact or shock loads
Radial loads
Axial loads
Inertial loads from payload movement
The inertia of the driven mechanism is especially important for robots. A joint moving a lightweight end effector has a different transmission requirement from a joint carrying a heavy payload at an extended arm position.
The operating cycle also matters. A reducer used continuously at moderate load may experience a different thermal and fatigue condition from one that repeatedly accelerates to high speed and reverses direction.
For this reason, suppliers should receive actual application data whenever possible. Providing only the desired reduction ratio and motor model may not be enough to select the appropriate transmission.
Planetary Reducers for Humanoid and Mobile Robots
The growth of humanoid robots, mobile robots, AMRs, and AGVs has increased demand for compact drive components that can be integrated into limited mechanical spaces.
Humanoid robots present particularly demanding requirements because their joints may need to combine compact dimensions, high torque density, rapid response, repeated motion, and controlled positioning. The transmission also needs to operate within a system where weight directly affects the energy required for movement.
Mobile robots have different requirements. Their drive systems may prioritize compact packaging, efficiency, durability, and reliable operation over long periods.
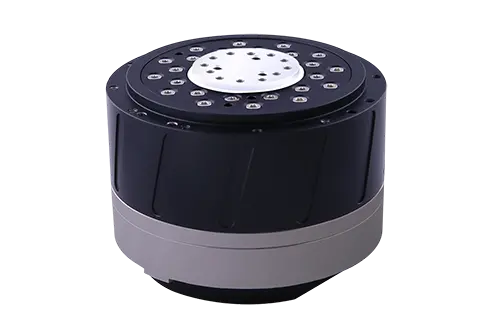
A planetary reducer can be integrated into these systems as part of a motor-reducer assembly or used as an independent transmission component, depending on the architecture.
The correct configuration depends on the mechanical interface, required torque, speed, control strategy, and available installation space.
Planetary Reducers in Industrial Automation
Planetary reducers are not limited to robots. They can also be used in industrial automation equipment, servo-driven machinery, packaging systems, machine tools, material handling equipment, and other precision motion systems.
In automated production equipment, repeatability and uptime are often more important than achieving the lowest initial component cost.
A reducer with stable mechanical performance can help reduce maintenance requirements and improve consistency between production cycles. This is particularly relevant when the machine operates continuously or when a transmission failure can stop an entire production line.
OEMs should therefore evaluate the reducer supplier as well as the product itself. Manufacturing capability, quality control, technical support, customization capability, and delivery lead time can all influence the success of a project.
Key Questions to Ask a Planetary Reducer Manufacturer
Before placing an order, technical buyers should request detailed information from the manufacturer.
Useful questions include:
1. What reduction ratios are available?
The ratio range should cover the speed and torque requirements of the intended motor and load.
2. How is backlash measured?
Backlash specifications should be accompanied by test conditions and measurement methods so that different products can be compared fairly.
3. What are the rated and peak torque values?
The supplier should distinguish between continuous operating torque and short-term peak torque.
4. What is the expected service life?
Service life depends on load, speed, operating cycle, lubrication, temperature, and other conditions. A supplier should explain the conditions behind the stated life.
5. Can the reducer match the selected servo motor?
Mounting dimensions, shaft configuration, flange specifications, and coupling requirements should be confirmed before production.
6. Can the transmission be customized?
For OEM applications, customized mounting interfaces or integrated drive solutions may simplify mechanical design and assembly.
7. What is the normal production lead time?
Lead time can become a major issue during prototype development and volume production. A stable supply chain is particularly important when the reducer is a core component.
Why Manufacturing Capability Matters
Precision transmission products require more than a good gear design. Manufacturing accuracy, assembly processes, inspection equipment, material control, and process consistency all contribute to the final performance of the reducer.
For OEM buyers, this means supplier evaluation should cover both technical specifications and production capability.
Liangzhi Joint focuses on robotic joint modules and precision transmission components, with R&D centers in Hangzhou and Shenzhen and production bases in Zhejiang and Dongguan. The company was officially launched in 2024, supported by a shareholder team with more than 20 years of industry and management experience.
Its product portfolio includes planetary reducers, harmonic reducers, humanoid robot joint modules, high-performance joint motors, and other drive components for robotics and automation.
The company's planetary reducer development includes high-precision products with a maximum stated accuracy of 1 arcminute, while its product development and manufacturing capabilities are supported by more than 30 national patents.
For international OEM customers, Liangzhi Joint also focuses on dimensions and performance designed to match commonly used European, American, Japanese, and Taiwanese transmission benchmarks. The company states an ultra-fast delivery cycle of approximately 5–7 days for applicable products and orders.
Choosing the Right Planetary Reducer for an OEM Project
For an OEM project, reducer selection should ideally take place early in the mechanical design process.
Start by defining the actual motion requirements:
Payload or driven mass
Required output torque
Maximum output speed
Acceleration and deceleration
Duty cycle
Required positioning accuracy
Installation dimensions
Expected operating life
Environmental conditions
Motor and encoder configuration
The next step is to calculate the required transmission ratio and verify the torque and speed range.
After that, engineers can compare suitable planetary reducer models based on backlash, rigidity, efficiency, load capacity, dimensions, and service life.
Finally, prototype testing should be used to verify the reducer under realistic operating conditions. Testing should include the expected payload, motion cycle, acceleration profile, temperature, and duty cycle rather than relying only on no-load testing.
This approach gives the OEM a more reliable basis for moving from prototype to volume production.
From Individual Reducers to Integrated Drive Solutions
Modern robot manufacturers increasingly require more than standalone mechanical components. They may need a complete drive solution that combines the motor, reducer, encoder, housing, and other components into a compact assembly.
This trend is particularly visible in humanoid robotics and compact robotic joints, where installation space is limited and integration can reduce the number of components that the OEM needs to source and assemble.
A supplier capable of providing both individual transmission components and integrated joint solutions can simplify mechanical development and supply-chain management.
For projects involving multiple robot axes, this can also help standardize component interfaces and reduce engineering workload during product development.
Conclusion
A planetary reducer can provide an effective transmission solution for robotics and precision automation when its characteristics are properly matched to the application. Torque capacity, reduction ratio, backlash, rigidity, speed, load conditions, service life, dimensions, and motor compatibility should all be considered before selection.
For a robotic precision reducer, the key question is not simply whether a product has a high torque rating or low backlash. The more important question is whether the complete transmission can provide predictable performance under the actual operating conditions of the robot.
OEMs and system integrators should therefore work with manufacturers that can provide detailed technical specifications, consistent manufacturing, customization support, and practical delivery capability.
Liangzhi Joint provides planetary reducers, harmonic reducers, robotic joint modules, and related drive components for robotics and automation applications. With R&D resources in Hangzhou and Shenzhen, production bases in Zhejiang and Dongguan, and a focus on high-precision transmission technology, the company supports customers developing robotic and intelligent motion systems.
For projects requiring a planetary reducer or a customized robotic transmission solution, technical specifications such as torque, speed, ratio, backlash, dimensions, motor interface, duty cycle, and expected quantity should be provided during the initial inquiry. This allows the supplier to recommend a configuration based on the actual application rather than a generic product selection.